Content last revised on September 17, 2026
PM100CLA120 Circuit Protection & Reliability: Calibrating Dynamic Braking Chopper Operation
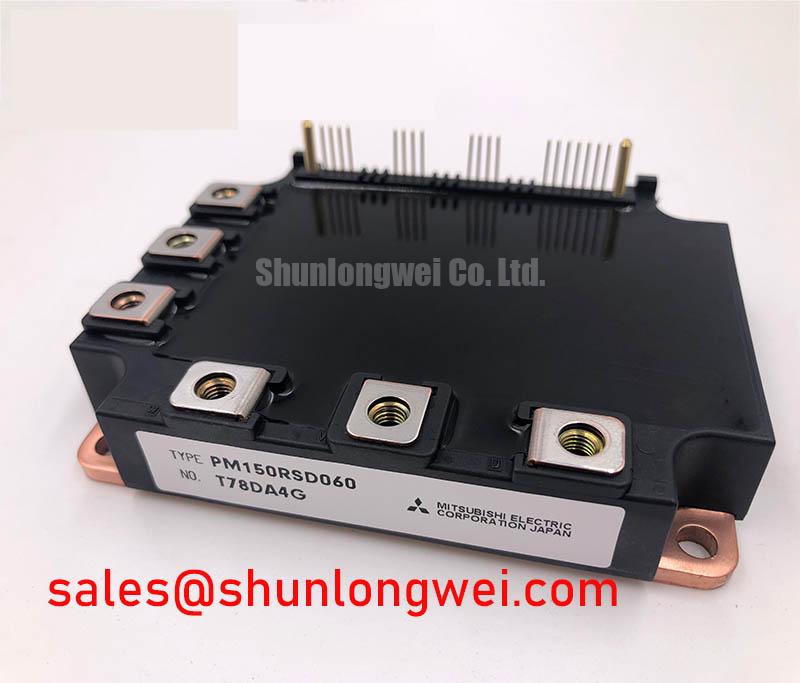
Before fitting a replacement, isolate the drive, inspect the baseplate and power terminals for damage or contamination, and confirm that the original inverter design requires a 1200 V, 100 A intelligent power module. The Mitsubishi Electric PM100CLA120 is specified for a collector emitter voltage of VCES 1200 V and a collector current of ±IC 100 A at TC 25°C, both Official Datasheet Specifications. Its stated peak collector current is ±ICP 200 A at TC 25°C, and the collector dissipation rating is PC 781 W at TC 25°C.
For maintenance planning, this module integrates control and protection functions within an IPM format, but its electrical ratings must be read together with the original inverter design, cooling condition, DC link arrangement, protection coordination, and control wiring. The official control supply specification is VD 15 V typical. The module’s documented protective functions include short circuit protection that trips when IC exceeds 150 A under VCIN 0 V and Tj 125°C, over temperature protection that trips above Tj 125°C, and under voltage protection that trips below VD 11.5 V. These functions support fault response but do not remove the requirement for correctly coordinated upstream fusing and system-level fault handling.
| Official Specification | Condition | Value |
|---|---|---|
| Collector Emitter Voltage, VCES | Specified rating | 1200 V |
| Collector Current, ±IC | TC 25°C | 100 A |
| Peak Collector Current, ±ICP | TC 25°C | 200 A |
| Collector Dissipation, PC | TC 25°C | 781 W |
| Control Supply Voltage, VD | Typical | 15 V |
| Isolation Voltage, Viso | AC one minute, terminals to baseplate | 2500 Vrms |
When an electric forklift or material-handling traction motor decelerates, regenerative energy can raise the DC link voltage if the battery path, contactor state, or energy-storage path cannot accept the returning current at that moment. A dynamic braking chopper, where used in the equipment architecture, transfers this energy into a braking resistor through a separately designed switching path. The PM100CLA120 must be assessed as part of the inverter power stage rather than assumed to be the braking chopper itself. The system integrator should verify the original schematic to establish whether braking control is external, integrated elsewhere in the drive, or handled through the battery-management and regeneration path.
Design Consideration: the braking resistor and its switching device need to tolerate the energy released during the actual deceleration profile, while the DC link capacitor bank must tolerate transient energy before chopper action becomes effective. A resistor with poor airflow, an interrupted thermal sensor circuit, a degraded DC link capacitor, or an incorrectly timed brake command can each contribute to unstable DC bus behavior. None of these conditions should be diagnosed from a single voltage reading. Compare recorded DC link behavior, motor command state, current feedback, and chopper command timing against a known-good machine or validated service documentation.
In a field inspection, examine the braking resistor enclosure for blocked ventilation, discolored wiring insulation, loose terminations, and evidence of moisture exposure. Check that DC link conductors are routed as paired outgoing and return paths where practical, because loop area influences inductive overshoot during current interruption. Clearance and creepage distances around the high-voltage bus should remain consistent with the original equipment insulation system; contamination, conductive dust, and condensation can reduce the effective margin even when the physical spacing has not changed.
Semiconductor fuse selection is a system-level protection task. A high-speed semiconductor fuse is commonly coordinated using its time-current and I²t characteristics so that a severe fault can be interrupted before conductors, busbars, and power semiconductors experience destructive energy. Engineering Recommendation: verify coordination from the original drive documentation and fuse manufacturer curves, including the prospective fault current available from the battery and DC link capacitors. The IPM short-circuit trip threshold is an Official Datasheet Specification, but it is not a substitute for external fault-energy limitation.
Freewheel-diode reverse recovery behavior can also affect conducted and radiated noise during motor current commutation. The recovery waveform, including its softness, is influenced by current, temperature, gate behavior, layout inductance, and the operating switching conditions. If ringing increases after a repair, use an appropriately rated differential measurement method to compare switching-node behavior with the validated signal path. A snubber or damping network should be evaluated from measured overshoot and ringing, not added solely because a generic circuit diagram shows one.
For topology comparison during repair evaluation, the SKIIP37AC12T4V1 can be reviewed as a separate power-module reference. Mechanical interface, terminal arrangement, pin logic, protection behavior, cooling requirements, and control architecture must all be verified before any substitution decision.
Assembly Integrity & Layout Architecture: Evaluating Isolation and Gate-Drive Routing for PM100CLA120
The official isolation rating for the PM100CLA120 is 2500 Vrms AC for one minute between terminals and baseplate. This is an Official Datasheet Specification for the module insulation path. It must not be interpreted as a declared reinforced isolation rating for the complete inverter, nor as evidence that an external gate-drive barrier meets a particular common-mode transient immunity level. The system designer should select and validate any external isolation barrier according to the complete control architecture, applicable installation standard, pollution environment, and measured switching transients.
In equipment that receives energy from an upstream rectifier or charger, line-frequency ripple and phase-related conduction behavior belong to the broader DC supply system. The traction inverter should be evaluated with its actual DC link impedance, capacitor condition, battery connection state, and charging interaction. A module replacement cannot correct weak DC link capacitance, poor rectifier connections, or a charger-control timing fault. The related CM100DY-12E may be useful as a neutral reference when reviewing associated rectification or complementary power-stage hardware, subject to the original circuit requirements.
Gate-drive isolation and power layout deserve separate inspections. Route control wiring away from high-current busbars where the cabinet layout permits, maintain clean separation between signal reference paths and noisy power paths, and inspect connectors for incomplete engagement or corrosion. If a controller has an isolated driver stage, verify its isolated supply stability during both startup and high-load switching. An apparently normal no-load control voltage can still collapse or become noisy when the traction motor is producing current.
RC snubbers are Design Considerations rather than official requirements for this model. They can reduce measured transient ringing in some inverter layouts, yet their resistor dissipation, capacitor voltage stress, and effect on switching loss must be verified in the finished system. Install them only where the original design specifies them or where controlled testing establishes a clear need. The Mitsubishi Electric application note on DIPIPM™ bootstrap circuit design provides useful manufacturer context on supply-path behavior; the PM100CLA120 installation should still follow its own applicable documentation and controller interface requirements.
⚠️ Maintenance Note: Periodically monitor terminal contact temperature rise and confirm that heatsink fins, fan paths, and cabinet air passages remain free of dust accumulation.
PM100CLA120 Operational Boundaries: Evaluating Differential Control-Loop Routing
Before altering any control return routing, confirm the actual terminal designations from the equipment schematic and the module documentation. An auxiliary emitter or Kelvin-emitter terminal must not be assumed for the PM100CLA120 unless it is explicitly identified in the applicable pinout. Where a drive design does provide a distinct low-current control return, Design Consideration is to keep that return separate from the high-current emitter or power-return path until the intended reference point. This reduces shared inductive voltage disturbance that can otherwise influence control thresholds during fast load-current transitions.
The practical objective is not a generic layout target but a measured result: minimize parasitic loop inductance to suppress turn-off overshoot and prevent unwanted control-loop disturbance, then verify peak voltage and gate-related waveforms during representative switching tests. High-current collector and emitter paths should be kept compact and mechanically secure. The DC link connection should provide a low-inductance current path close to the inverter stage, while control harness routing should avoid sharing return paths with power cabling.
For a returned machine with intermittent overcurrent or desaturation-related behavior, begin with observable conditions. Inspect power terminal fasteners, busbar flatness, thermal interface condition, capacitor connections, and controller plugs. Measure the control supply at the module interface while the machine is commanded through a controlled load condition. Use an oscilloscope only with probes and measurement practice suitable for the voltage environment. Oscillation, recurring overshoot, or unexpected gate-related noise may indicate layout coupling, a degraded driver supply, connector resistance, or a measurement setup limitation; cross-check against the known-good phase or a validated waveform.
The 781 W collector dissipation figure is specified at TC 25°C and should not be treated as an available continuous loss budget inside a closed industrial enclosure. Actual thermal performance depends on heatsink flatness, thermal interface coverage, airflow, ambient condition, load profile, and control behavior. During preventive maintenance, check for uneven thermal compound distribution, hardened interface material, fan degradation, and condensation risk after temperature cycling. Any rework should preserve the equipment manufacturer’s mounting method and insulation arrangement.
For broader technical context on the relationship between switching devices, voltage class, and three-phase conversion design, consult The 1200 V CoolSiC™ MOSFET Advantage in Three. That reference does not establish equivalent electrical or mechanical compatibility with this IPM; it serves as an engineering background resource for system-level evaluation.
Preventing Spurious Faults: Dynamic Gate Impedance Control Guidelines for PM100CLA120
The PM100CLA120 control inputs and internal protection behavior should be treated as an IPM interface, not as exposed discrete IGBT gates. Do not apply negative gate-bias practices intended for discrete transistor gate terminals to this module’s control inputs unless the original Mitsubishi Electric interface documentation specifically requires and permits that arrangement. The official control supply is 15 V typical, and the undervoltage protection function trips below 11.5 V. These values should guide supply verification, while the controller’s permitted input levels and timing must be confirmed from the original drive design.
High switching-node dv/dt can capacitively couple into nearby low-level control wiring and may create spurious switching commands or nuisance protection events. Engineering Recommendation: use dedicated driver architecture, clean reference routing, appropriate interlock logic, and physical separation of sensitive control conductors from high-current paths. Whether active Miller clamping, gate impedance adjustment, or another suppression method is appropriate depends on the actual driver topology and the module interface. Verify the result with controlled waveform measurement rather than applying a universal damping value.
In forklift traction service, rapid direction changes, regenerative braking, vibration, and frequent thermal cycling can expose marginal connections. Inspect input connectors, control-supply wiring, motor-cable termination, chassis bonding, and coolant or airflow provisions according to the equipment’s service schedule. Moisture control is also important: water ingress or condensation near control connectors can create leakage paths and intermittent behavior that resembles a semiconductor fault. Allow the enclosure to reach a dry, stable condition before electrical testing where condensation is suspected.
The documented over-temperature protection threshold is Tj above 125°C, and short-circuit protection trips under the stated test condition when IC exceeds 150 A. These functions help define the module’s official protection features, but they do not characterize every overload waveform or every wiring fault. When a protective trip occurs repeatedly, retain fault-code history where available, inspect the cooling and power path, then verify control-supply stability and switching behavior under a controlled operating condition before replacing additional parts.