Content last revised on September 21, 2026
Assembly Integrity and Layout Architecture for Dynamic Braking Chopper Operation
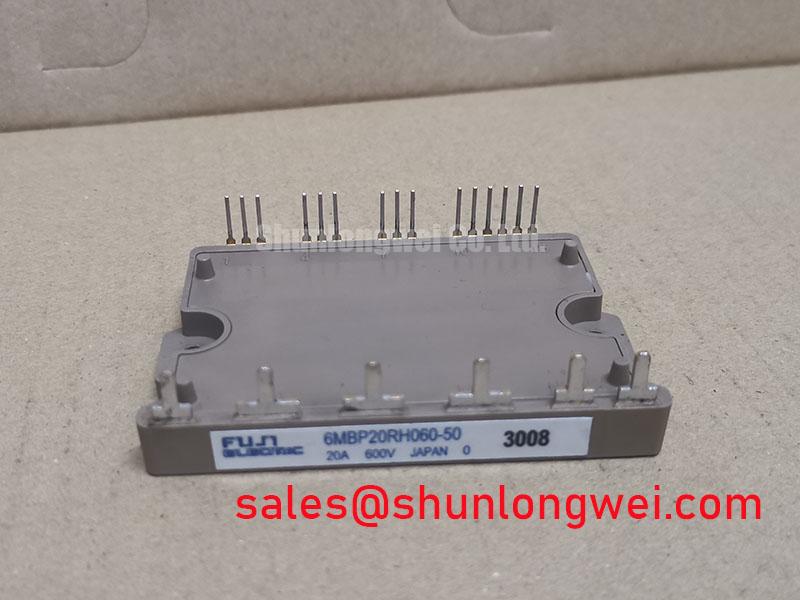
| Manufacturer | Fuji Electric |
| Model | 6MBP20VAA060-50 |
| Product category | IPM Module |
| Collector emitter voltage | 600 V, Official Datasheet Specification |
| Continuous collector current | 20 A, Official Datasheet Specification |
| Collector power dissipation | 103 W at 25°C case temperature, Official Datasheet Specification |
| Isolation voltage | AC 2500 Vrms for 1 minute, Official Datasheet Specification |
| Mounting torque | 1.3 to 1.7 N·m for M4 screws, Official Datasheet Specification |
Check the braking path with the DC link discharged: measure for unintended continuity between the power terminals, inspect the resistor connections, and compare the chopper gate signal with the controller reference before energizing the drive. A missing or continuously active braking command can place abnormal stress on the switching path, while an open ballast resistor can leave regenerative energy uncontrolled.
The 6MBP20VAA060-50 is specified for a 600 V collector emitter voltage, 20 A continuous collector current, and 103 W collector power dissipation at a 25°C case temperature. These are official device ratings, not a complete braking system envelope. The actual braking duty depends on motor inertia, stopping profile, DC link voltage, repetition rate, resistor pulse capability, enclosure temperature, and the thermal path from the module base to the heatsink.
For a light industrial automation axis or multi-joint robotic articulator, the braking IGBT and ballast resistor should be evaluated as one energy-handling network. Determine the mechanical energy released during deceleration, then confirm that the resistor can absorb the required pulse energy without exceeding its own thermal and voltage limits. The switching device must also be checked against the resulting DC link excursion during the complete stop cycle. This is an Engineering Recommendation; the module’s 20 A current rating alone does not establish the permitted braking resistor value or stop frequency.
Keep the high-current commutation loop compact. The DC link connection, braking switch, and resistor return should use a low-inductance physical arrangement, with the gate-drive wiring routed separately from the power conductors. Minimize parasitic loop inductance to reduce turn-off overshoot, then verify the peak collector emitter voltage with a properly rated differential probe during the hardest commanded stop. The measured peak must remain within the system’s validated switching margin relative to the official 600 V VCES rating.
Clearance and creepage are layout responsibilities rather than values that can be inferred from the product name. The system designer should evaluate the working voltage, pollution level, material group, altitude, enclosure conditions, and applicable insulation standard before fixing the board or busbar geometry. Do not use the module’s AC 2500 Vrms isolation voltage as a direct substitute for a finished assembly’s creepage or clearance requirement.
For troubleshooting, record the DC link voltage, braking command, resistor temperature trend, and collector emitter waveform in the same test run. If the chopper turns on but the DC link remains elevated, inspect the resistor circuit, contactors, fuses, and current path rather than assuming an IGBT failure. If the voltage spike appears only during rapid deceleration, compare the busbar arrangement and probe connection with a known stable setup; measurement-loop inductance can distort the observed waveform.
The related 6MBP100TEA060-50 may also be reviewed as a separate Fuji Electric module for applications requiring a different current class. It should be treated as an independent selection subject to its own ratings, mechanical dimensions, gate-drive requirements, and thermal validation.
Benchtop Waveform Tuning and Baseplate Mounting Control
With power removed and the DC link verified discharged, inspect the baseplate contact pattern, mounting-hole condition, and thermal interface before interpreting switching waveforms; uneven clamping can create both thermal error and electrical stress that appears to be a gate-drive problem.
The official mounting requirement for this module is 1.3 to 1.7 N·m for M4 screws. Apply the torque progressively and in a balanced sequence so the baseplate seats evenly against the heatsink. The contact surfaces should be clean, flat within the limits defined by the mechanical design, and free from particles that could locally lift the module. Thermal interface material should be applied as a controlled, uniform layer appropriate to the selected compound or pad. Excess material can increase thermal resistance, while incomplete coverage can create hot spots.
Baseplate convexity compensation is a mechanical integration issue, not an invitation to force the package flat with excessive screw torque. If the heatsink or module base does not mate evenly, correct the mechanical stack-up through approved surface preparation or an appropriate interface solution. Verify contact pressure and thermal behavior after assembly rather than relying only on visual inspection.
During a benchtop switching test, examine the gate emitter voltage directly at the module terminals and place the probe loop close to the actual gate-drive connection. A waveform that looks clean at the driver board can ring at the module because of wiring inductance and common return impedance. Gate-drive source and sink capability should be checked against the selected switching speed, gate charge, protection delay, and driver thermal limits. These values are system-dependent and are not specified by the five official parameters provided for this product.
An external gate resistor can be used as a Typical Starting Point for bench tuning, but its final value should be selected from measured rise and fall behavior, turn-off overshoot, switching loss, and gate ringing. Increase damping only while confirming that switching loss and device temperature remain acceptable. A resistor that suppresses ringing but causes excessive turn-off loss may shift the problem into thermal stress.
Use a controlled double-pulse or equivalent laboratory test only when the fixture, probe, supply, and fault protection are suitable for the energy involved. Compare the collector emitter waveform at different bus voltages and currents, and examine the effect of cable length and busbar position. The general relationship between stray inductance, current slew rate, and voltage overshoot is useful for diagnosis, but the final operating limits must come from measured system behavior and the module documentation.
⚠️ Maintenance Note: Recheck heatsink cleanliness, thermal-interface condition, and terminal tightness during scheduled service, especially where dust, vibration, high humidity, or condensation can alter contact temperature.
Preventing Spurious Faults with Desaturation Detection
When a protection trip occurs, capture the gate signal, collector emitter voltage, DC link voltage, and driver fault output together before replacing the module; this separates a genuine overcurrent event from a noisy desaturation circuit, insufficient blanking behavior, or a disturbed gate return.
Desaturation protection is a system-level function and should not be represented as an official feature or timing guarantee unless it is explicitly confirmed in the applicable Fuji Electric documentation. The supplied product parameters establish voltage, current, dissipation, isolation, and mounting torque, but they do not establish a universal short-circuit withstand time or a guaranteed detection interval for every driver arrangement.
For an industrial drive, the protection network should detect abnormal collector emitter voltage while accounting for diode recovery, switching transients, driver propagation delay, and the selected blanking behavior. The designer should validate the complete protection chain under controlled short-circuit and overcurrent conditions using an appropriate test method. Any stated short-circuit limit must come from the applicable device data and test conditions, not from a generic IPM assumption.
A two-stage soft turn-off strategy can be considered where the gate driver and protection architecture support it. The first action limits gate charge and reduces the current transition rate; the second action completes turn-off after the protection decision. This is an Engineering Recommendation, not a guaranteed internal function of the 6MBP20VAA060-50. The resulting collector emitter overshoot must be measured against the DC link and official voltage rating.
False trips often require inspection of the sensing diode path, local decoupling, gate return routing, driver isolation, and the physical distance between the power loop and protection signal. Keep protection traces away from high di/dt conductors and provide a clean reference path. If the fault output changes state without a corresponding abnormal power waveform, compare the driver supply at the module location with the driver reference and check whether common-mode transients are entering the protection channel.
For field diagnosis, record whether the event occurs at startup, steady torque, rapid acceleration, regenerative braking, or only after thermal rise. A temperature-related event may involve heatsink airflow, interface degradation, switching loss, or load profile rather than a single defective component. Thermal imaging and case-temperature measurements should be correlated with the electrical waveform, while the module’s 103 W PC rating at 25°C case temperature should not be extrapolated directly to a hotter assembly without thermal analysis.
Engineers reviewing switching protection principles may consult the The Ultimate IGBT Knowledge Base as a technical reference. For semiconductor technology context, Fuji Electric’s Power Semiconductors and ICs resource provides manufacturer information across relevant device families.
Derating Evaluation and Mismatched Parameter Control
At the test bench, compare the phase or braking current waveform, gate timing, collector emitter voltage, and case temperature under matched operating points before changing the module; mismatched wiring or unequal thermal contact can imitate a current-sharing defect.
The 20 A continuous collector current rating is an official specification, while the usable current in an assembled drive depends on switching frequency, duty cycle, case temperature, cooling performance, protection settings, and the selected operating waveform. A derating assessment should therefore begin with measured conduction and switching losses, not with a fixed percentage copied from another module family.
In parallel switching arrangements, the positive temperature coefficient commonly associated with IGBT saturation voltage can support static current sharing, but it does not eliminate dynamic imbalance. Gate-loop impedance, emitter return inductance, propagation delay, busbar symmetry, and thermal coupling all influence transient current distribution. Match the physical length and routing of the gate-drive paths, keep the power paths symmetrical, and verify each device’s gate waveform at its own terminals.
When a multi-device arrangement shows unequal current, inspect the complete commutation path. Measure gate voltage relative to the correct emitter reference, compare turn-on and turn-off timing, and check whether one device has a different thermal interface or heatsink contact. The collector emitter waveform should be reviewed for unequal overshoot, ringing, or delayed turn-off. Avoid correcting the imbalance solely by changing gate resistance until the mechanical and layout causes have been excluded.
Long motor cables introduce additional system behavior, including distributed capacitance, impedance mismatch, and reflected voltage at the motor terminals. If a robotic axis or automation drive uses a long cable, verify the motor-end waveform and cable termination conditions rather than measuring only at the inverter. Output filtering may be evaluated when the measured reflected-wave stress exceeds the motor insulation or inverter design margin, with the filter selected from the complete drive, cable, and motor characteristics.
High-voltage insulation also requires an assembly review. The module provides AC 2500 Vrms isolation for one minute under its specified test condition, but the finished equipment still requires suitable spacing, contamination control, enclosure management, and production testing. Condensation prevention, airflow direction, and periodic cleaning are practical design considerations for equipment operating through high and low temperature cycles.
For accelerated qualification work, HALT and HASS methods can help structure stress-screening discussions, but they do not replace the Fuji Electric device ratings or establish field life for this module. The HALT and HASS reference should be used as background methodology only, with stress levels, acceptance criteria, and failure analysis defined by the equipment manufacturer.