
Content last revised on October 5, 2026
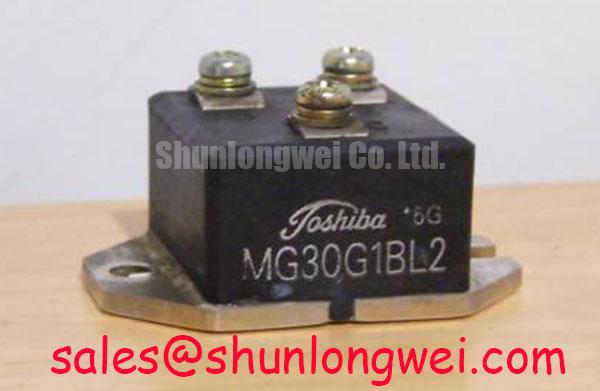
MG30G1BL2 Thermal Electrical Optimization for Motor Braking
| Specification | Official Value |
|---|---|
| Manufacturer | Toshiba |
| Part Number | MG30G1BL2 |
| Category | IGBT Module |
| Rated Voltage | 600.0 V |
| Rated Current | 30.0 A |
| Package | Toshiba Module |
Measure the cold resistance and inspect the power terminals before testing a braking circuit, then compare the switching waveform and DC link response with a known-good actuator channel. The official device ratings are 600.0 V and 30.0 A; these values identify the component boundary, but they do not by themselves define the allowable braking pulse, duty cycle, ballast resistance, or cooling arrangement.
For a precision stepper or BLDC servo actuator, the braking path must be assessed against the motor’s stored kinetic energy, DC link capacitance, regenerative voltage rise, and braking resistor thermal capacity. Designers should verify whether the application uses an internal or external braking route rather than assuming a particular topology from the module part number. During commissioning, monitor the DC link during deceleration and check that the measured peak remains within the complete system’s validated switching and insulation limits.
Thermal cycling deserves attention when the actuator repeatedly accelerates and stops. Inspect the heatsink contact pattern, mounting flatness, thermal interface condition, and mechanical clamping after a controlled run. A resistor that is correctly rated for average power may still experience excessive pulse stress, while an IGBT that remains below its nominal current can see damaging junction temperature swings if the cooling path is uneven.
⚡ Field Alert: Isolate DC power before disconnecting the module, follow the fastener manufacturer’s torque specification, and apply the thermal interface material as a uniform thin layer.
When a replacement evaluation is necessary, the MG100Q1ZS40 can be reviewed as a related Toshiba device, but voltage, current, terminal arrangement, gate-drive behavior, and mechanical fit must be verified independently rather than treated as interchangeable.
Field Diagnostics and Commissioning for High dv/dt Shoot Through
Probe the gate to its local emitter reference and observe both complementary switching commands while the DC link is disabled, then repeat the measurement at controlled operating voltage with suitable differential probes. Unexpected gate movement during the opposite device’s transition may indicate common-mode coupling, insufficient gate-loop damping, driver-ground displacement, or a layout-related impedance problem.
A low-inductance gate-return path is a Design Consideration for suppressing ringing and false turn-on. The driver should be evaluated for active Miller control, controlled turn-off behavior, and a negative off-bias only when those functions are supported by the complete gate-drive architecture and verified against the module’s gate-emitter limits. The requested bias value must come from the system design and the applicable Toshiba documentation; it should not be assumed from general IGBT practice.
Short-circuit protection should combine desaturation sensing with a deliberately managed soft turn-off sequence. The protection designer must validate blanking, detection, fault propagation, and energy during the turn-off event using the actual driver, wiring, DC link, and load. A nominal response-time target cannot be assigned to this module without its authoritative switching and short-circuit data.
For the associated rectifier or high-power front end, engineers may review the neutral system relationship of MG150Q1JS40. It should be evaluated as a separate topology element, with its own voltage stress, commutation behavior, cooling, and protection coordination.
Operational Boundaries Under Pulsed Thermal Stress
Capture collector-emitter voltage, current, case temperature, and pulse duration during the heaviest validated deceleration event, then compare the measured waveform against the thermal model used for the servo drive. A single heatsink temperature reading cannot establish junction margin because transient thermal impedance, mounting quality, pulse repetition, and neighboring heat sources all influence the result.
Engineering Calculation may be used to estimate peak junction temperature from the measured case temperature and the applicable transient thermal impedance network, but the thermal coefficients must come from the authorized Toshiba technical documentation. A multi-RC model is useful only when its time constants and resistance values represent the actual module and mounting interface. Avoid substituting a steady-state resistance for a short regenerative pulse.
Inspect solder joints, busbar interfaces, terminal discoloration, and heatsink contact after thermal cycling. Unequal current sharing in parallel IGBTs can arise from differences in gate-loop impedance, emitter path inductance, device temperature, or timing. Designers should keep the power paths geometrically balanced and verify dynamic sharing with current probes rather than inferring it from average load current.
Overvoltage coordination should be checked as a network: the DC link capacitor, wiring inductance, snubber, MOV, braking branch, and semiconductor fast fuse each address a different part of the fault or switching event. Fuse selection requires an I2t comparison with the complete fault path and the module’s validated short-circuit withstand data; a fuse label alone does not establish protection against every failure mode.
Reliability documentation and test methods should be aligned with recognized semiconductor practice. The JEDEC standards resource can help identify relevant testing frameworks, but it does not replace the Toshiba data applicable to this specific module. If the servo equipment includes an industrial display, white-point calibration remains a separate panel task; the color temperature reference is relevant to display optics, not IGBT electrical ratings.
Circuit Protection and PCB Symmetry in IGBT Gate Returns
Check the gate-return voltage directly at the module terminals while recording the main emitter current, because a shared copper return can create ground-bounce that is invisible at the driver board. Separate the high-current emitter route from the low-noise gate reference wherever the module terminal arrangement and PCB construction permit it.
This is a Design Consideration rather than a guaranteed internal feature: do not assume a dedicated auxiliary emitter or Kelvin connection exists unless the Toshiba terminal documentation confirms it. If the available package provides separate control and power returns, route the gate loop as a compact, controlled path and keep it away from the commutation loop. If it does not, the system engineer must characterize the resulting common-mode voltage and compensate through layout, driver placement, filtering, and validated switching speed.
Measure turn-on and turn-off ringing at the module pins, not only at the driver output. Gate resistance, ferrite elements, clamp behavior, and negative off-bias can be tuned only after the actual oscillation frequency, overshoot, and fault response are observed. The Evolution of Negative Off-Bias Gate Drive Circuits provides useful background for evaluating this method, while the final settings remain dependent on the complete power stage.
During final commissioning, verify creepage, clearance, insulation barriers, MOV placement, fuse coordination, and enclosure contamination controls against the system voltage and applicable standards. Confirm that the selected MG30G1BL2 package, terminal orientation, heatsink interface, gate-drive connection, and protection behavior all match the original servo actuator design before returning the equipment to service.